Why autorotation
A helicopter that loses its engine can still land: the air flowing up through the rotor keeps it spinning, and the spinning rotor brakes the fall. We wanted to know whether a rocket could do the same, because a rotor can be steered and a parachute cannot. For a reusable launcher, that means landing somewhere precise without carrying extra fuel.
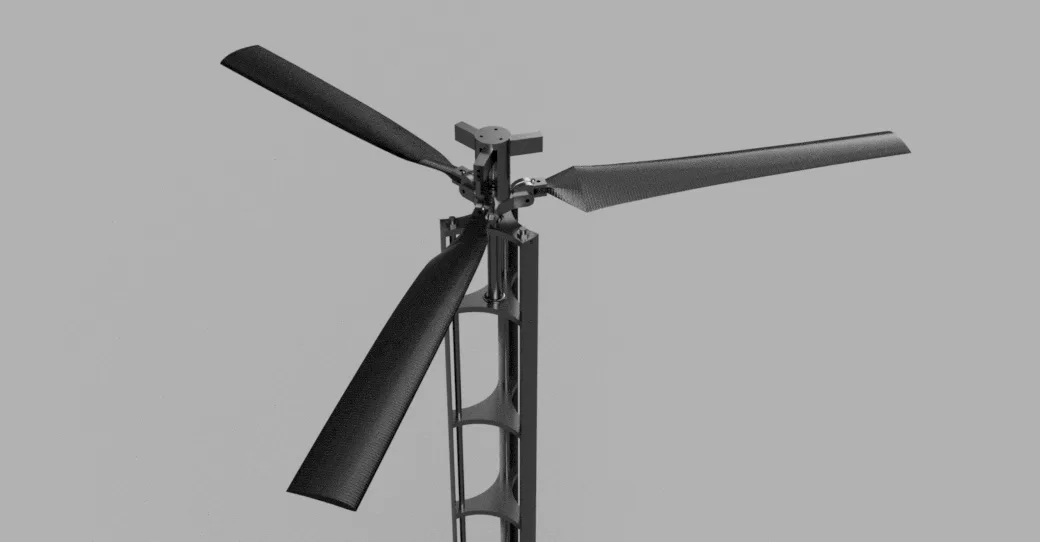
Getting the blades out
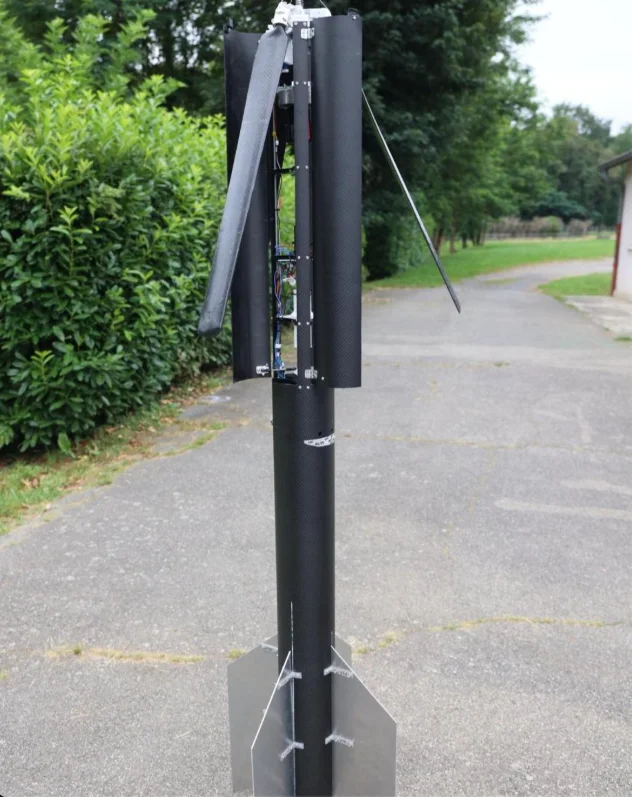
The hardest part of the design was the opening system. During the climb the blades have to stay inside a 152 mm tube. At apogee three doors, cut out of the carbon body, swing open on hinges, all driven by one servo, and springs push the blades out. I sized that servo myself: aerodynamic load plus hinge friction gave 1.2 N·m in the worst case, so we took a 2.4 N·m Hitec HS-7954SH.
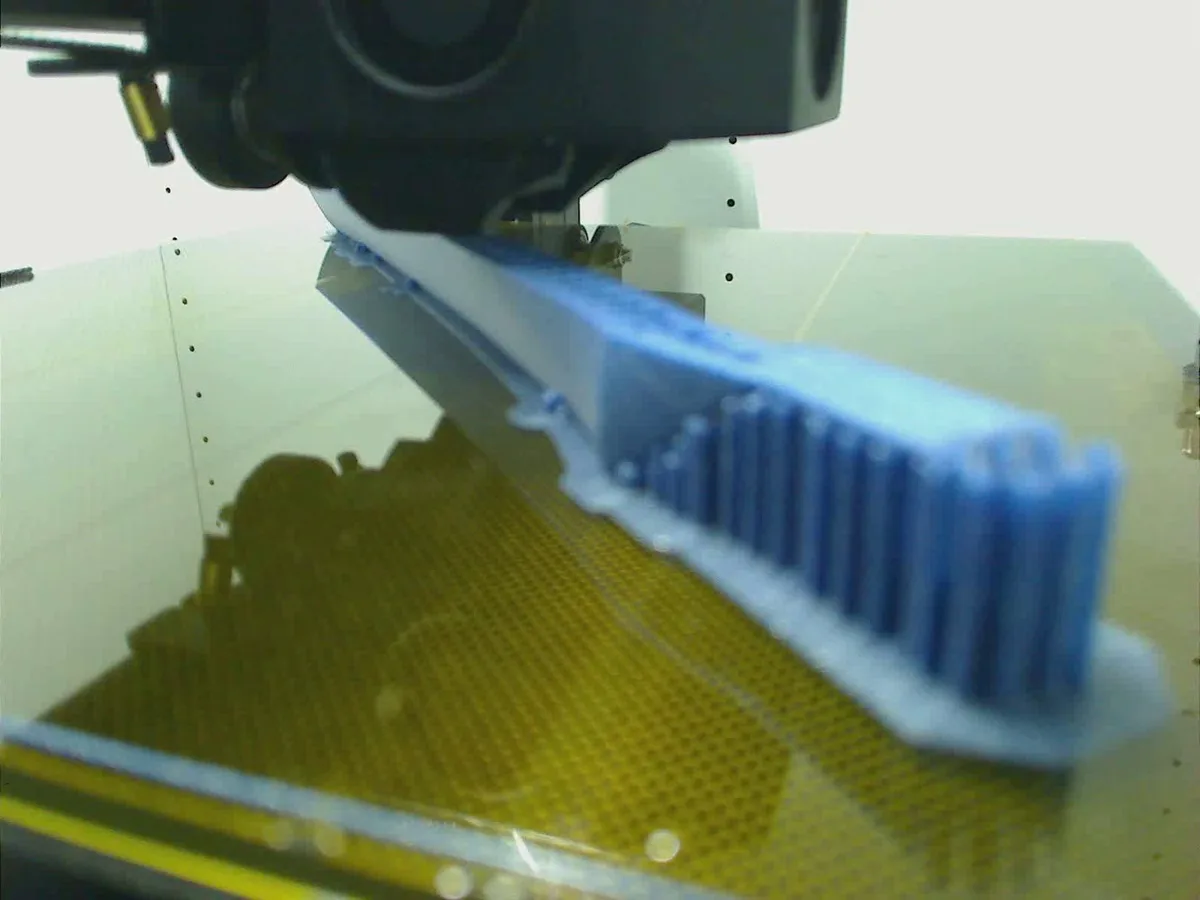
The blades were the other headache. To autorotate, each blade has to be twisted along its 70 cm, with the angle varying along the span. We optimised the twist with a blade-element model and tested a half-scale 3D-printed rotor on the roof of a car: the model overestimated the force by up to 33%. The real blades are a carbon tube spar, a foam core and a carbon/epoxy skin. A destructive test on a sample gave a safety factor of about 2, the minimum C'Space accepts.
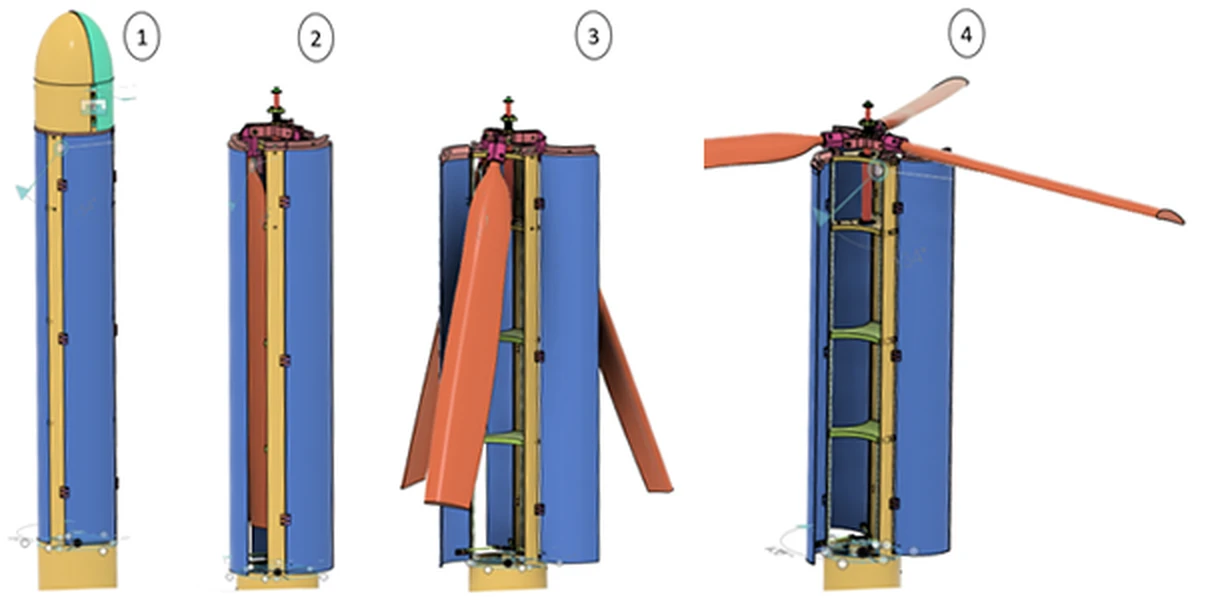
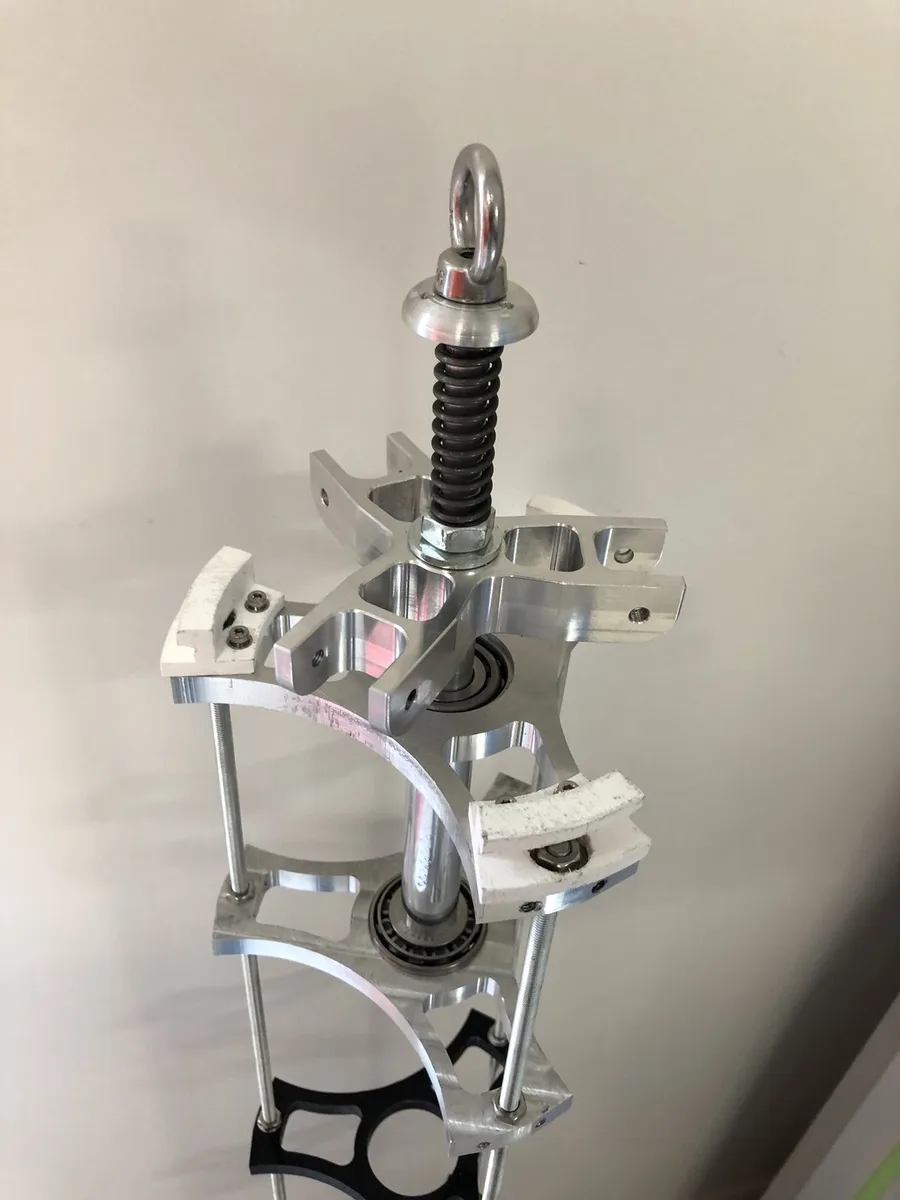
A timer instead of sensors
The original flight computer detected apogee with a barometer and an accelerometer. I replaced it with a plain timer: launch is detected when the umbilical jack is pulled, the nose cone is released 8 s later, and the doors open 5 s after that. Our trajectory simulation already told us when apogee would come, and with the launch date close we preferred to spend our time on the mechanics rather than debugging electronics.
Launch day
Since autorotation recovery was new to the campaign, the CNES safety team had to accept a rocket without a main parachute. They did, after we showed the rotor kept the descent speed within limits. We launched on 21 July, in the afternoon, less than a minute before the launch window closed. The climb was clean and straight. Then the rotor only partly deployed: the line of the small parachute that flips the rocket got caught in the blades. The rocket never turned the right way up and hit the ground at full speed. We did recover the footage from the onboard cameras.
What I would do differently
Test the whole deployment on the ground first, on a full-size mock-up with the real lines and the real parachute. And go step by step: one flight with a standard parachute, then one where we control the deployment, and only then the rotor. We tried to fly three new things at once.